Recon Rover / The build journal
Every build.
Every breakthrough.
From a single gearmotor to a rover out in the field. Follow the experiments, discoveries, and refinements that brought Recon Rover to life.
Select a thumbnail or title to watch on YouTube. Descriptions are from the original video pages.
 BUILD LOG / 01
A Monster Gearmotor with 24V Power Supply
This will be part of a larger project - the Recon Rover - that will be able to go to a GPS waypoint and navigate around obstacles, with differential steering (skid-steer like a bobcat or a tank), and so on. Also includes a buck converter for the electronics package involved, and a simple test to see if the motor startup current does or does not affect the buck converter's 5V output.
 BUILD LOG / 02
PWM Testing of Gearmotor for Recon Rover
This is further work with the gearmotor, now controlling speed with Pulse-Width-Modulation and direction control via an H-Bridge. Going to have two such motors in my final Recon Rover experiment.
 BUILD LOG / 03
Rolling Out the Black Carpet...
Scaffolding, batteries, and a neoprene mat for the Recon Rover project
 BUILD LOG / 04
Gearmotor running on LiPo batteries instead of wall power converter
This is a video of my gearmotor running on LiPo batteries, along with a buck converter with a voltage meter attached to verify voltage stability when running a high-current load.
 BUILD LOG / 05
The wheeeeel!!! Finally looking like something…
Finally the wheel has come in the mail and I have something that’s starting to look like a real Recon Rover!
 BUILD LOG / 06
Now it’s a hot mess! Further development of the Recon Rover…
A quick and dirty bread board based version of the electronics to be used in my recon Rover and a test run of the motor speed controller called an H bridge with a wheel attached to the motor. Also, including a hook up to my laptop, where it displays the current being drawn by the electronics and the motor.
 BUILD LOG / 07
Now it’s a hot mess! But it works! Another development in the Recon Rover…
No description provided on YouTube.
 BUILD LOG / 08
It all fits! Electronics and motors fit just right in the chassis! #diyelectronics
HahahaHA! It all fits inside the chassis! With not an inch to spare. Just right. This is the humble beginnings of the Recon Rover!
 BUILD LOG / 09
One expansion board finished! #diyelectronics #robotics
Here is a finished (but does it work?) expansion board for my microcontroller setup that measures the temperature of whatever I want inside the Recon Rover chassis - 4 temperature probes at a time, connected to an I2C ADC breakout board.
 BUILD LOG / 10
Motors and wheels assembled! #diyelectronics #robotics
Finally drilled the holes in the aluminum chassis and mounted the motors! Starting to look like something real now…
 BUILD LOG / 11
It’s got its guts! #diyelectronics #robotics
It's really starting to look like a robot now, it's got its guts, motors, and wheels
 BUILD LOG / 12
Motor full test - and a failed H-Bridge. Crap. #diyelectronics #robotics
Here we have a full motor test with no load except the wheels themselves. And a surprise - a blown h-bridge channel, ok it was cheap, going to get a RoboClaw ST 2x45A and do this for real. Lol.
 BUILD LOG / 13
The Recon Rover has its turret! #diyelectronics #robotics
The Recon Rover project has developed quite nicely, it now has a turret and a radio and a camera and a floodlight with room for more! Nicer h-bridge too.
 BUILD LOG / 14
The Recon Rover makes R2-D2 style noises as it is controlled by a wifi link!
My Recon Rover is progressing rapidly as it now gives audio feedback when it receives commands from a serial link and then passes the commands on to the Recon Rover via a Wi-Fi link. It also connects to a camera module, which reports whether or not it is ready to take pictures, and can take pictures from the command prompt.
 BUILD LOG / 15
Recon Rover Maiden Voyage
The Recon Rover going on its maiden voyage - down the hall!!!
 BUILD LOG / 16
Turning on a dime! The Recon Rover is working perfectly!
The Recon Rover gets its first test of turning in place as a skid-steer should. And it works!!!
 BUILD LOG / 17
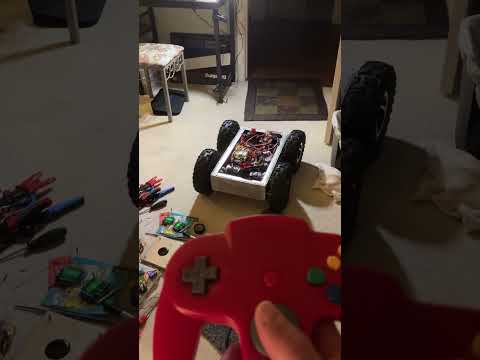
Recon Rover now controlled by an N64 Controller!
The Recon Rover now has an N64 controller that controls its movement, controls taking photos, the spotlight, and the turret direction (when the turret is finished)
 BUILD LOG / 18
The Stress Test - Can it carry me?
The stress test is a grand success… the Recon Rover can carry all 220lbs of me and didn't even get up to top speed!
 BUILD LOG / 19
Spotlight working! Wow that's bright!
Testing out the constant current power supply with the spotlight LED COB light
 BUILD LOG / 20
Turret Assembly & Spotlight Control Implemented!
The turret assembly is now completed, but not motorized. The spotlight is controllable from the N64 controller.
 BUILD LOG / 21
LoRa Radio Link from N64 to Recon Rover
The latest development on the Recon Rover is a LoRa radio link between the N64 controller and the Rover turret. Features a tiny postage stamp sized microcontroller and dual OLED displays.
 BUILD LOG / 22
Rat’s nest be gone! Pro PCBs!
OK so where we’re at with the Recon Rover is new, fully functioning professionally made circuit boards replacing all the breadboards and messy wiring. (Ok, there’s still a lot of wires) and… a newly minted 5mm pitch pulley for the turret!
 BUILD LOG / 23
N64 Remote for Recon Rover Finished!
Well, it ain't pretty - but it works. My N64 Remote Control for the Recon Rover is now complete. May need to do some software revisions later, but for now it works great! You'd think I could have lined up the OLED displays more centered, but oh well.
 BUILD LOG / 24
Partially finished Recon Rover with working turret and mobility
No description provided on YouTube.
 BUILD LOG / 25
Sensor stack almost complete!
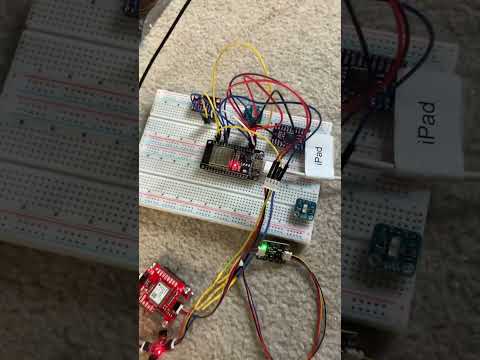
The sensor "stack" (minus the already implemented temperature sensors on the main rover chassis) for the Recon Rover is working beautifully. GPS, light sensors, environmental sensor, IMU, and (not pictured) microphone, with a multiplexer to facilitate the multiple light sensors which each have a fixed address and cannot be read from independently without a mux.
 BUILD LOG / 26
Recon Rover Wireless Firmware Updating and Brief Intro to the LiDAR #lidar #robotics
The Recon Rover now has OTA firmware updating for its several microcontrollers all over a WiFi connection, and you get a brief, accidental intro to the LiDAR functionality of the Rover.
 BUILD LOG / 27
Auto center turret with Hall Effect sensor
Showing off the Recon Rover’s turret auto-centering feature via a Hall effect sensor and a magnet. Totally cool.
 BUILD LOG / 28
The Sensor Tower is Complete! Now time to add some sensors!
Showing off the Recon Rover’s sensor tower finally completed with two decks and four posts and the first sensor to be attached: a LiDAR module!
 BUILD LOG / 29
The beginnings of the UAV catch-bowl!
The first quarter of the UAV landing bowl has been 3D printed (took 11 hours!) and matches up nicely with the Recon Rover rear end. lol.
 BUILD LOG / 30
A 3D printed enclosure for my temperature reading module
Here’s a great example of what a 3D printer can do for you… a custom enclosure for a custom circuit board for reading temperatures of four thermistors over an I2C connection, with a snap in place cover. Protects circuit solder joints from shorting out on the interior of the chassis of the Recon Rover’s or a motor or something else conductive.
 BUILD LOG / 31
The Recon Rover can hear the direction of a sound!
Yes, that’s right, the Recon Rover can detect whether a sound is coming from the left, right, or center of the turret! Sometimes it can’t tell (ambiguous) but it works pretty reliably with loud vocalizations (yelling) and it will soon have three mics and the ability to give a heading direction in the direction of the sound! They are temporarily affixed to the turret with electrical tape but will soon be bolted in place. Cool!
 BUILD LOG / 32
Recon Rover hears and responds to noises by taking a photo!
Yup. Even better. Not only does the Recon Rover know where a sound is coming from - it also turns its turret towards the sound and takes a photo! Not the best photo quality in a dimly lit room but it works!
 BUILD LOG / 33
The sensor tower is now complete
Yup - the sensor tower is working perfectly and the robot will soon have its first outdoor test! Just need to wait for a couple of circuit boards to come in the mail and it will have motion detection built in as well, on the four sides of the Recon Rover with fresnel lens passive infrared motion detection. We’re nearing the home stretch!
 BUILD LOG / 34
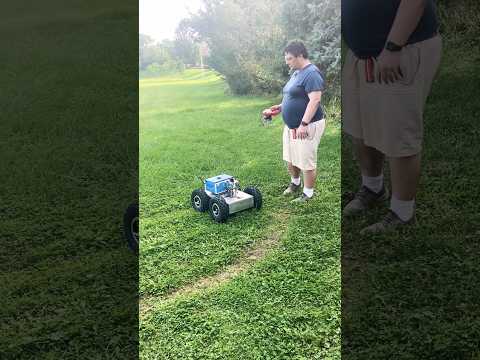
Recon Rover outdoor test!
An outdoor test of the (almost) completed Recon Rover. We attracted a dog. We were not able to test the mission software on my iPhone yet but that is still to come!
 BUILD LOG / 35
The Recon Rover is tearing it up!
The Recon Rover is tearing it up in the tall grass and driving through the underbrush! Quick test of the turret motion, too.
 BUILD LOG / 36
Recon Rover w/ Mission Control & PIRs
A brief run down on the Recon Rover Mission Control page hosted on the main ESP32 inside the robot. Also an update on PIR sensors.
The journey continues
Built. Tested. Still evolving.
See the Projects playlist for new updates, or talk with us about the platform.